RobotDraw
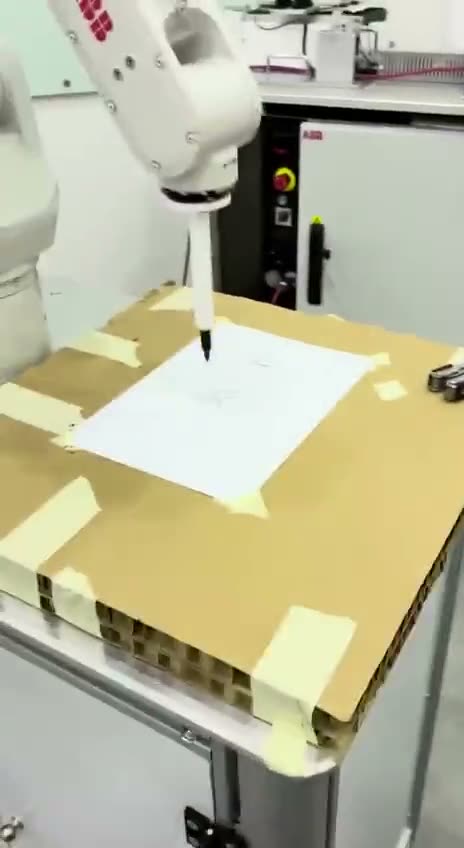
SVG-to-RAPID converter for six-axis ABB industrial robots. A Python and Flask tool that turns vector artwork into readable RAPID drawing programs with safe lift and traversal moves, then estimates run time. Hardware-validated on an IRB 1100 across five drawings, including one of roughly 3,000 strokes.
RAPID (ABB robot programming) RobotStudio Python Flask Industrial Robot Programming Offline Programming (OLP)